Open to funded PhD positions

Mohamed Saleh

Researcher in predictive control and spiking neural networks. Hannover, Germany.

I am a researcher working at the intersection of control systems and machine learning. My work spans real-time Model Predictive Control and energy-efficient spiking neural networks, applied to unstable robotic systems and multimodal perception. I am drawn to new challenges across domains, with a research interest centered on optimal and learning-based control, safe control and verification, data-driven modeling, and efficient machine learning.

━ state  ┅ predicted horizon ▮ LIF population code
Selected projects

Key academic projects

Each project runs from first principles to a verified result, with the numbers reproducible from the code.

Control · RoboticsM.Sc. thesis and embedded timing study · 2024–2026

Embedded real-time nonlinear Model Predictive Control of an unstable robot

Constrained nonlinear MPC for a two-wheeled self-balancing robot, running in real time on embedded hardware.

  • acados Real-Time Iteration: 143× faster than offline IPOPT (0.88 ms vs. 125 ms) with the same closed-loop performance.
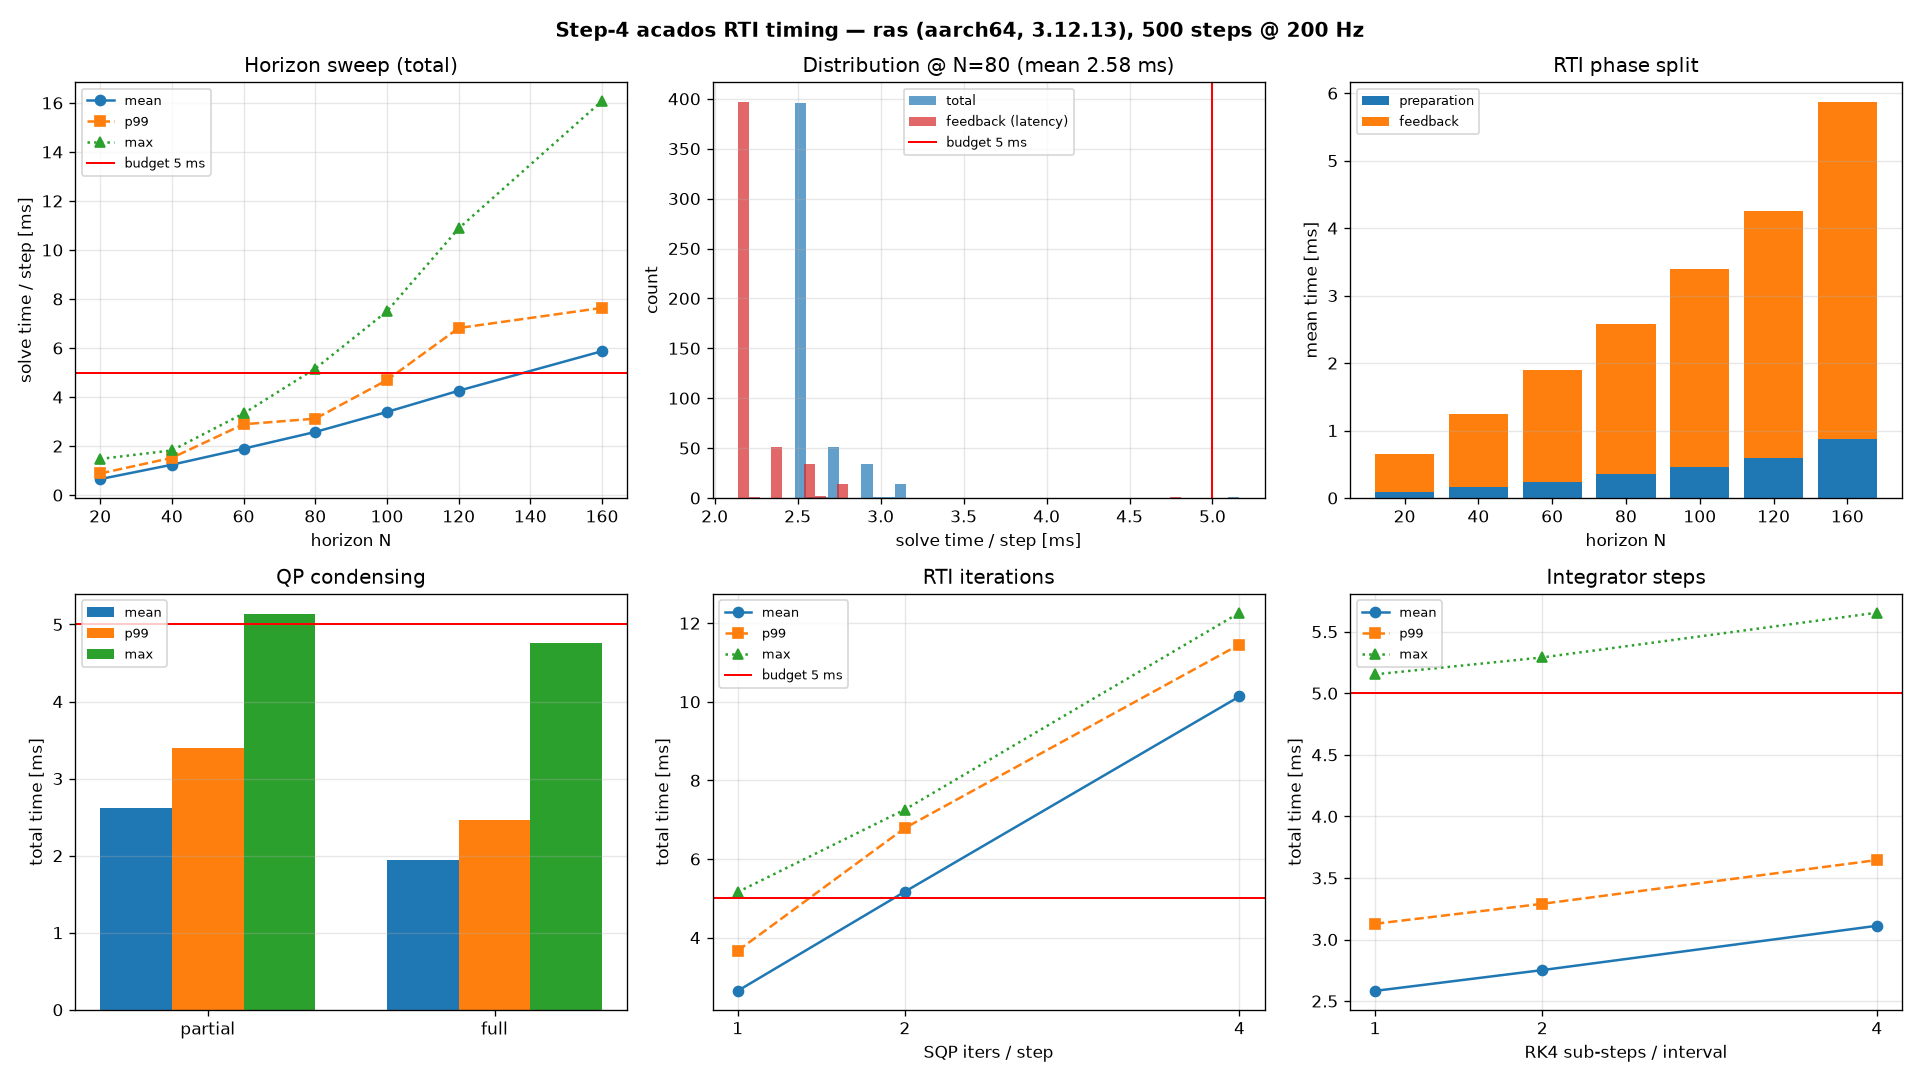
  • Runs at 200 Hz on a Raspberry Pi within a 5 ms budget: mean 2.58 ms, p99 3.12 ms.
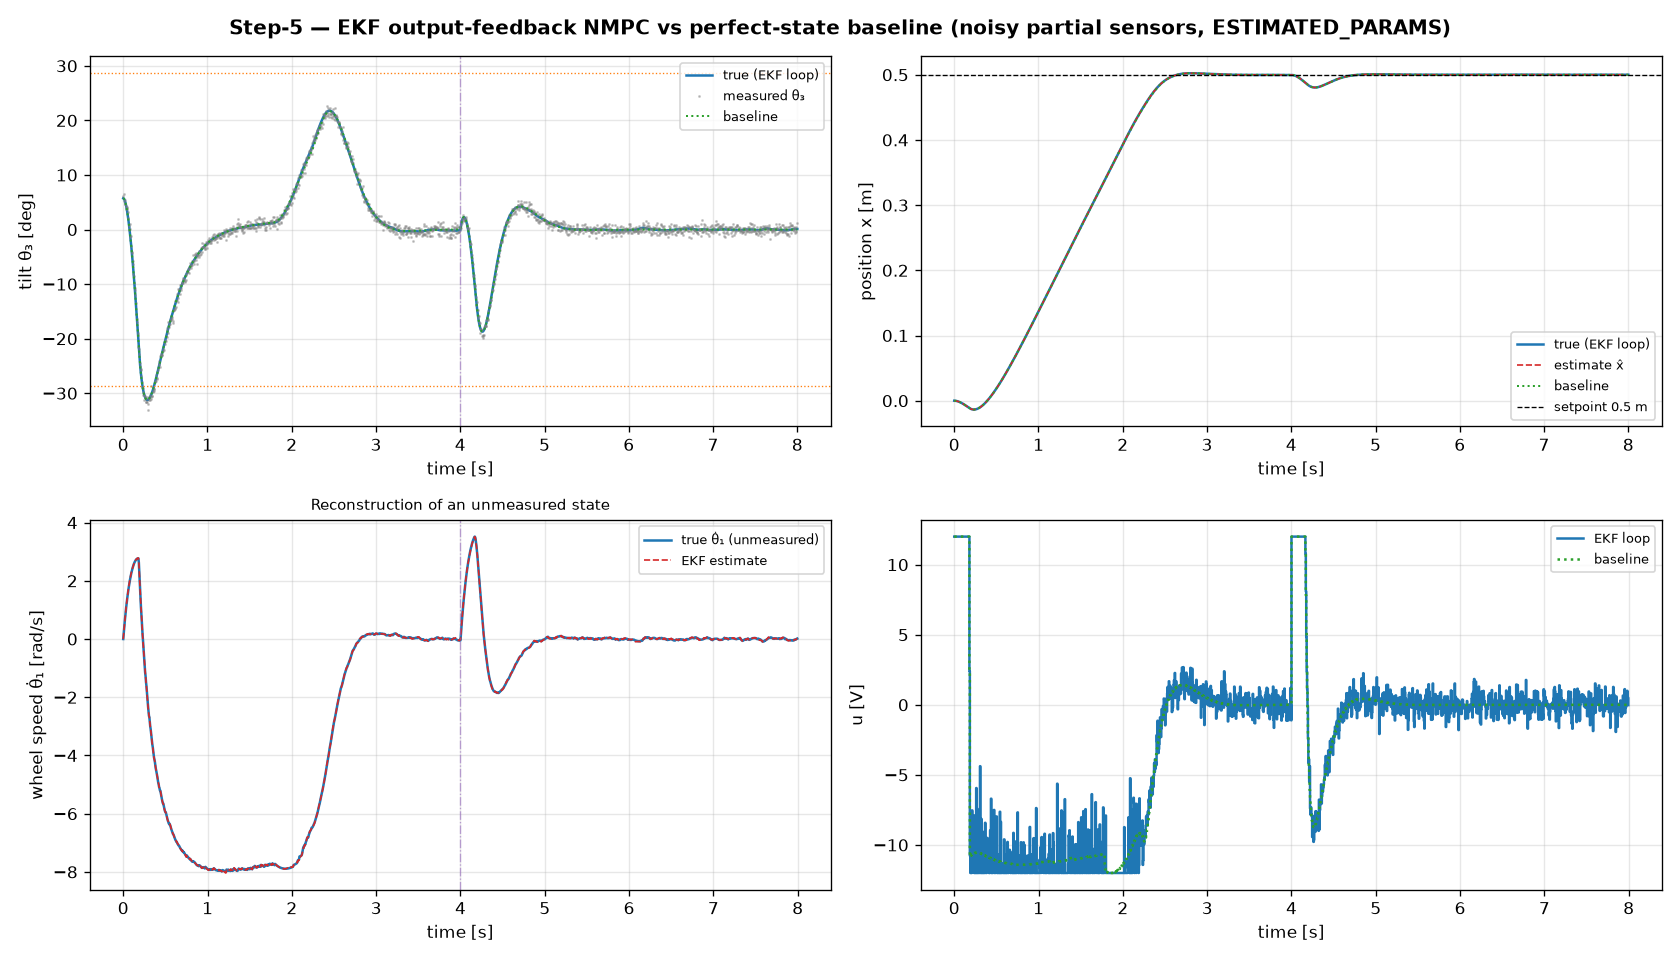
  • Lagrangian model identified from sensor data (88–91% fit on held-out experiments), with an Extended Kalman Filter closing the loop.
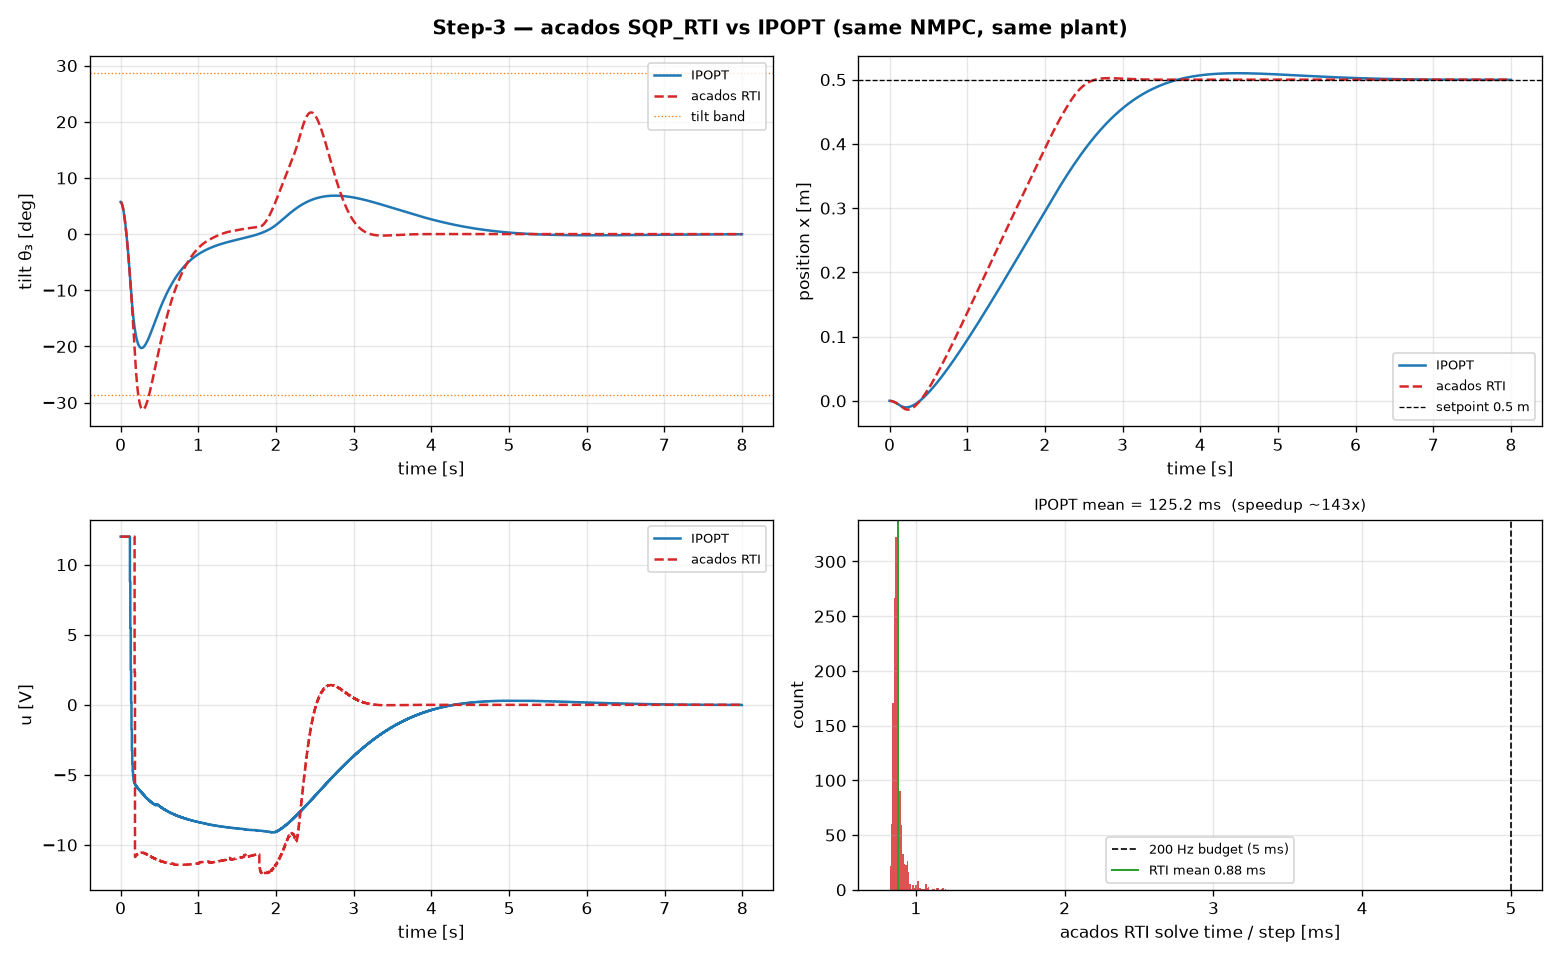
Tilt, position, and input trajectories for acados RTI versus IPOPT, plus a histogram of RTI solve times centered at 0.88 ms against a 5 ms budget
Same NMPC, same plant. The RTI controller tracks the 0.5 m setpoint faster and every solve lands far inside the 5 ms budget.
Watch the robot balanceHardware demo on YouTube
Machine learning · NeuromorphicPLRI, MHH Hannover · 2025

SNNergy: energy-efficient deep spiking neural network for multimodal audio-visual learning

An energy-efficient spiking network that fuses audio and video at every scale.

  • CMQKA cross-modal attention built from binary spikes, linear O(N) instead of quadratic O(N²).
  • First hierarchical multi-scale cross-modal fusion network in spiking computing.
  • State-of-the-art accuracy among multimodal SNNs at an estimated energy below the ANN baselines.

Top-1 accuracy · audio-visual benchmarks

CREMA-D+0.83 pts over best SNN
SNNergy78.38
TAAF-SNNs77.55
AVE+1.49 pts over best SNN
SNNergy72.14
TAAF-SNNs70.65
UrbanSound8K-AV+1.38 pts over best SNN
SNNergy99.66
CMCI98.28

Compared with the previous best SNN on each benchmark.

Scientific computingComputational electromagnetics · 2026

FDTD solver for dispersive, time-varying media

A 1D solver for Maxwell's equations in a medium that is both dispersive and modulated in time.

  • Yee-scheme solver with a Drude dispersion model, built from scratch.
  • Each stage verified against a closed-form reference: the Airy sum, Drude reflectance, and temporal Fresnel coefficients.
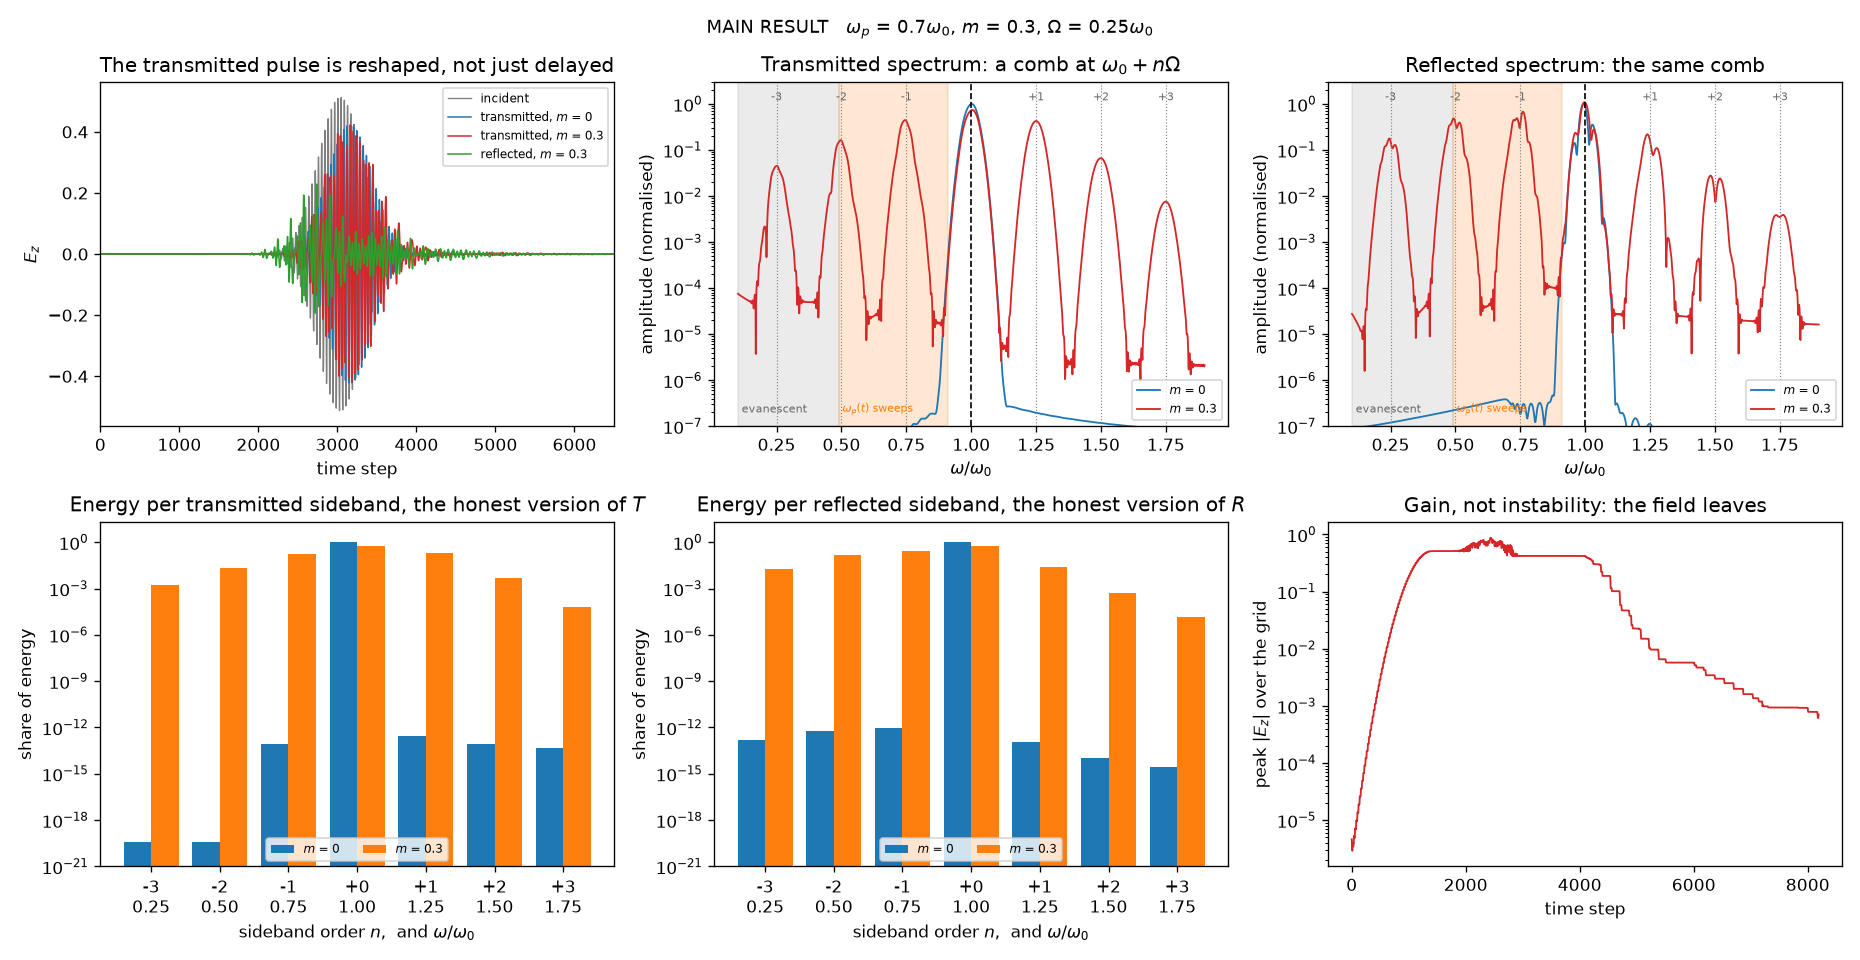
  • Resolves the sideband comb of a pulse crossing a modulated medium, with measured second-order convergence.
Main FDTD result: reshaped transmitted pulse, transmitted and reflected spectra showing a sideband comb, energy per sideband, and peak field over time
Main result. ωp = 0.7 ω₀ modulated at Ω = 0.25 ω₀ with depth m = 0.3. The carrier keeps 60.5% of the transmitted energy and the first sidebands take 17.0% and 19.7%.
Multi-agent controlB.Sc. project · 2018

Cooperative control of a multi-agent system for Industrial IoRT

Centralized feedback control of three mobile robots in simulation. B.Sc. project, Distinction, funded by ASRT.

Publications

Papers

One publication appears under the transliteration Muhammad Hassan, an earlier spelling of my name.

2026

Cross-Modal Binary Attention: An Energy-Efficient Fusion Framework for Audio-Visual Learning Under review

Mohamed Saleh, Zahra Ahmadi

Submitted to Information Fusion (Elsevier)

2024

Modeling and Parameters Estimation of a Self-Balancing Two-Wheeled Vehicle Journal

Muhammad Hassan, Ahmed Mahmoud Moustafa, Mohammed Moness

Journal of Advanced Engineering Trends 43(1), 373–381

Experience and education

Path so far

From Minia, Egypt, where I studied, researched, and taught for five years, to research in Hannover.

Research and teaching

  1. Apr. 2025 – Oct. 2025 · Hannover, Germany

    Research Associate

    Peter L. Reichertz Institute for Medical Informatics (PLRI), MHH. Supervised by Dr. Zahra Ahmadi.

    • Identified multimodal audio-visual learning as an underexplored direction within energy-efficient spiking neural networks and independently scoped the research problem that became the SNNergy project.
    • Conducted a comprehensive literature review spanning spiking transformers, multimodal fusion strategies, and neuromorphic computing.
    • Co-authored the manuscript, under review at Information Fusion, and presented the work at an institute-wide research exchange.
  2. Feb. 2019 – Mar. 2024 · Minia, Egypt

    Researcher and Teaching Assistant

    Faculty of Engineering, Minia University

    • Conducted M.Sc. research on real-time MPC, gray-box system identification, and hybrid modeling of an unstable wheeled robot, from embedded implementation on hardware to experimental validation.
    • Independently taught Embedded Systems (C/C++) and a Machine Learning elective, and assisted senior faculty in Digital Control Systems, Systems Analysis, and Operations Research (LP/MILP).
    • Mentored student teams from data preprocessing to embedded deployment.
    • Took on departmental responsibilities alongside teaching, including department meetings, lab administration, and exam supervision.
  3. 2017 · Cairo, Egypt

    Machine Learning Internship

    IBM Egypt

    • Built and deployed a recommendation system with Flask on IBM Developer Cloud.

Education

2024 · Minia University

M.Sc. Electrical Engineering (Computers and Systems)

Thesis: Optimal Hybrid Control for Unstable Robotic Systems. Supervised by Prof. Mohammed Moness and Dr. Ahmed M. Moustafa. Graded coursework: Distinction in Systems Engineering, Advanced Programming, and Hybrid Dynamical Systems.

2018 · Minia University

B.Sc. Computer and Systems Engineering

Graduation project on cooperative multi-agent control for Industrial IoRT, graded Distinction.

Distinction with Honors · Ranked 1st in class

Awards

  • 2018ASRT research fund for the B.Sc. graduation project on multi-agent robotic control
  • 2018Ranked first in class, B.Sc. Computer and Systems Engineering
Toolkit

Methods and tools

English: fluent and professional, written and spoken. German: beginner level (A1).

Control and optimization

Linear and nonlinear MPCRobust MPCQPCasADiacados (RTI/SQP)HPIPMIPOPTLQR / LQGEKF / UKFLyapunov analysis

Modeling and system identification

Lagrangian modelingGray-box identificationDMDcSensitivity analysisState-space modeling

Machine learning

Deep learningSpiking neural networksTransformersMultimodal fusionSurrogate-gradient trainingGPU-cluster training

Embedded and real-time systems

Raspberry PiArduinoMicrocontrollersIMU sensor fusionH-bridge motor controlProcessor-in-the-loop

Programming and tools

Python (NumPy, SciPy, PyTorch)SpikingJellyC / C++MATLAB / SimulinkBashGitLinuxDockerLaTeX
Contact

Let's talk research.

I am looking for funded PhD positions in robotics, optimal control, and machine learning. References are available on request.